publications

Generative robot learning and assistive sensing.

2026

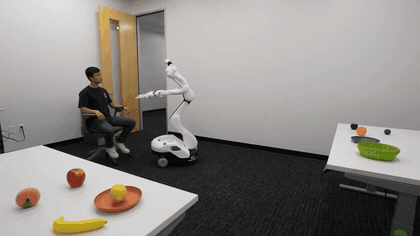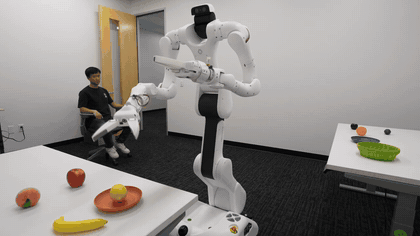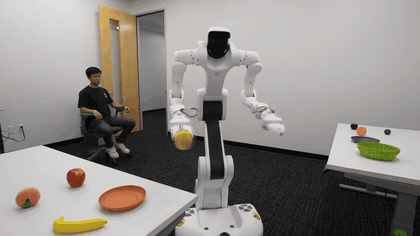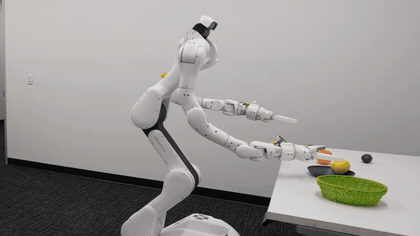
  1. Orbit montage of generated physical human-robot interaction scenarios
    GenPHRI: Agentic Generative Simulation for Physical Human-Robot Interaction

    GenPHRI turns a single prompt into a simulated human, environment, robot, and motion, supporting zero-shot prompt2sim2real transfer for real-world caregiving tasks.

    Junxiang Wang*, Nir Pechuk*, Xinwen Xu*, Tiancheng Wu, Nayon Kim, Julian Millan, and Zackory Erickson

    * Equal contribution

    Preprint, 2026
  2. A real-world robot moves a lemon to a blue plate in the MeMoREval memory benchmark
    What Should Embodied Agents Remember? Benchmarking and Evaluating Memory Modality for Embodied Agents

    MeMoREval benchmarks how memory modality affects embodied agents across 53 tasks, measuring task success and the inference costs of building and using memory.

    Junxiang Wang, Yuchen Liu, Yi Wu, Guofei Chen, Nir Pechuk, Tao Chen, Zackory Erickson, Yuzhe Qin, and Tianyu Li
    Preprint, 2026
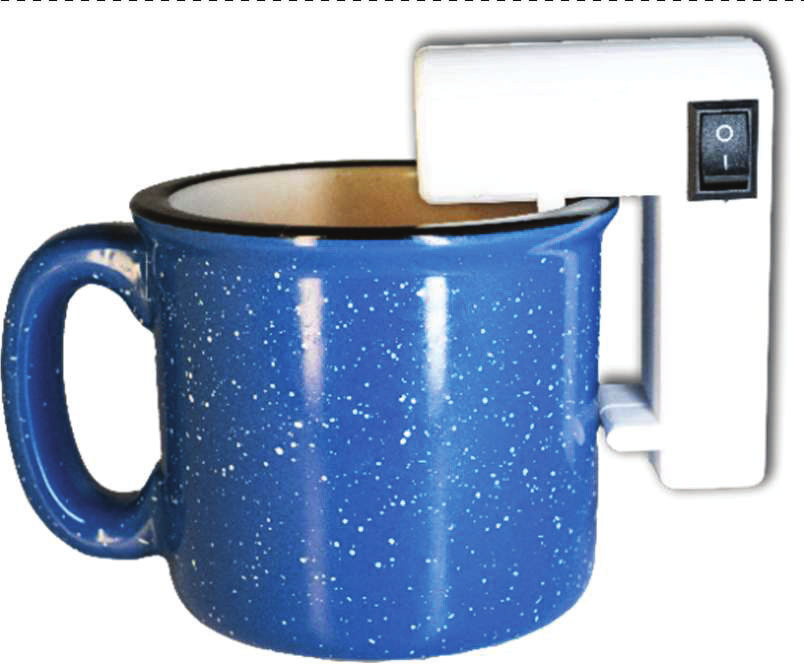
  3. Spill-O-Not: A contactless material level indicator for visually impaired users

    The Galina / Spill-O-Not project uses contactless LiDAR time-of-flight sensing and audio feedback to help visually impaired users avoid overpouring.

    Maxwell Mamishev, Nir Pechuk, Rayhan Shaik, and Braden Miller
    Journal of Physics: Conference Series, 2026

2020

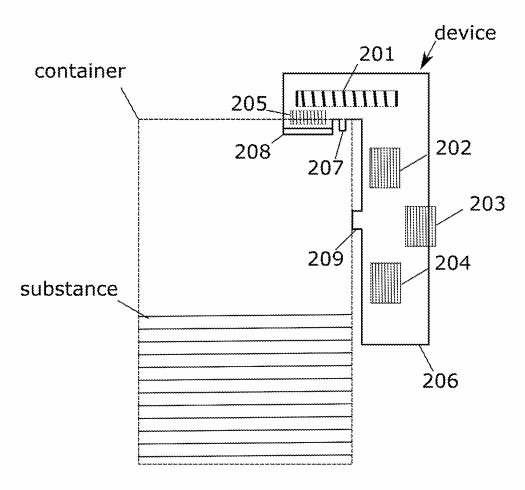
  1. Container filling or emptying guidance device

    A contactless sensing device monitors changing material levels and provides feedback to guide container filling or emptying and help prevent spills.

    Nir Pechuk, Ron Pechuk, and Maxwell A. Mamishev
    U.S. Patent No. 10,830,626 B2, Nov 2020